SenseGlove R1
Haptic hand control and force perception for robotic teleoperation
Keep in mind Specifications are sourced claims, not our independent performance measurement.
Compare up to 10 devices across categories. Keep the purpose and the source beside the numbers.
676 models available. Showing nine - search to narrow the list.
Lowest recorded store prices take priority over announced or launch prices, within the selected source market. Currencies use the dated EUR reference rates. Deposits and recurring charges are excluded from price order; missing prices stay last. Original price records remain visible.
Haptic hand control and force perception for robotic teleoperation
Keep in mind Specifications are sourced claims, not our independent performance measurement.
Electrostatic braking and fingertip feedback for virtual grasping
Keep in mind ETH press release says up to40 N, while the research abstract states20 N; the narrower paper figure is retained and the discrepancy disclosed.
Published specifications and documented constraints. See the full comparison below for prices and sources.
Scroll across the table to compare every model
| Haptics & body trackingAdd a model | 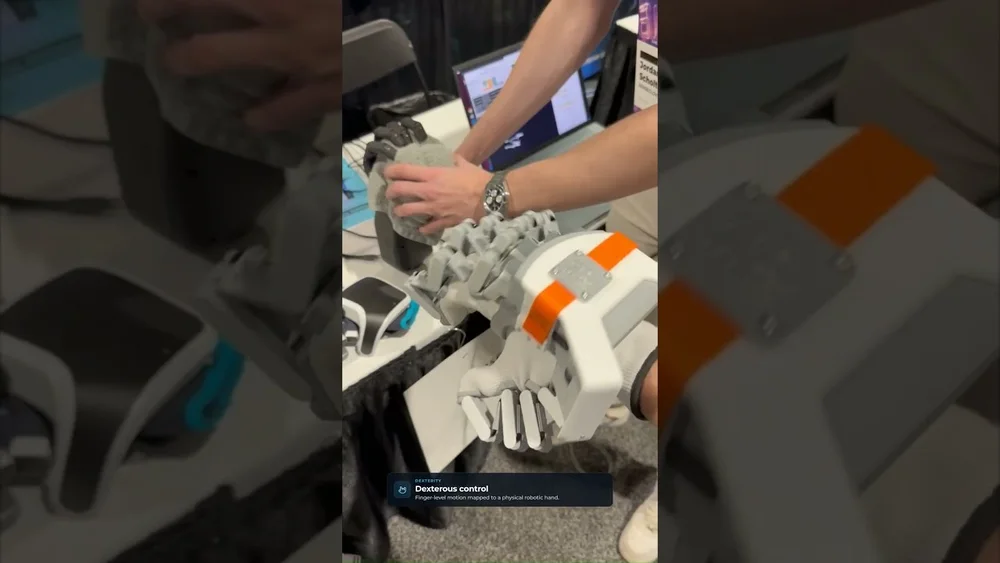 | 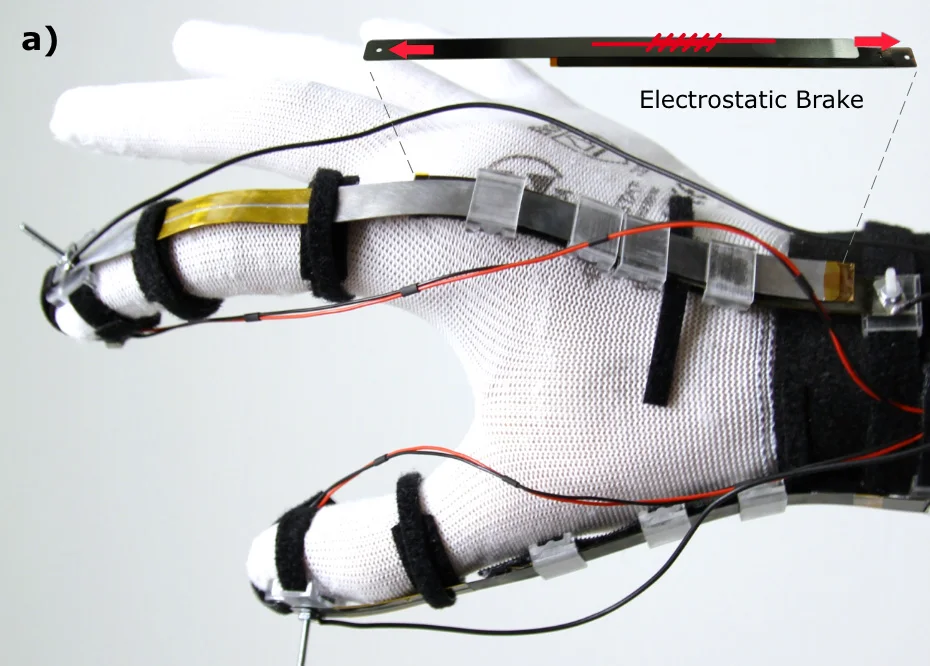 |
|---|---|---|
| Prices · all markets | Price not verified 0 offer records & sourcesNo verified price in this audit. | Price not verified 0 offer records & sourcesNo verified price in this audit. |
| Designed for | Haptic hand control and force perception for robotic teleoperation ↗ | Electrostatic braking and fingertip feedback for virtual grasping ↗ |
| Form factor | Instrumented force-feedback glove ↗ | Thin glove-mounted research apparatus ↗ |
| Power & output | Not verified | Externally cabled prototype; possible battery use was future work ↗ |
| Weight | Not verified | Less than 8 g for the described haptic glove mechanism ↗ |
| Force Feedback | Four degrees of freedom of active force feedback ↗ | Not applicable to this category |
| Control Rate | 1 kHz sample rate and force-control loop ↗ | Not applicable to this category |
| Finger Tracking | Raw exoskeleton tracking data updates at 1,000 Hz; the maker documentation says positional accuracy refers to the linkages, not finger tracking. ↗ | Not applicable to this category |
| Pressure Sensing | Real-time pressure sensing ↗ | Not applicable to this category |
| Vibration | Eight LRA actuators: one on each of five fingertips and three in the palm strap. ↗ | Not applicable to this category |
| Mounting | Standalone use or mounted to a haptic arm ↗ | Not applicable to this category |
| Sdk | Python API and ROS workspace for Windows and Linux. ↗ | Not applicable to this category |
| Wrist Tracking | No built-in 3D position tracking; a third-party tracker or robotic arm must be mounted. ↗ | Not applicable to this category |
| Link Box | Separate link box powers up to two R1 devices and connects them to a PC as a USB hub. ↗ | Not applicable to this category |
| Host Connection | An available USB-C port is required. ↗ | Not applicable to this category |
| Research Year | Not applicable to this category | 2018 ↗ |
| Brake | Not applicable to this category | Electrostatic attraction between flexible elastic metal strips ↗ |
| Holding Force | Not applicable to this category | Up to 20 N per equipped finger in the authors’ research abstract ↗ |
| Mounted Digits | Not applicable to this category | Index finger and thumb using articulated3D-printed guides ↗ |
| Cutaneous Feedback | Not applicable to this category | Piezoelectric actuators at the fingertips ↗ |
| Construction | Not applicable to this category | Fabric glove, elastic metal strips and insulating layer ↗ |
| Availability | Manufacturer labels R1 Available Now and requests a quote. Commercial professional hardware; no public complete-device price verified. | 2018 physical research prototype. No consumer release or public device purchase price verified. |
| Important context |
|
|
| Editorial pick & release | No editorial ranking recorded | No editorial ranking recorded |
| Evidence | Manufacturer source Checked 2026-10-13 | Manufacturer source Checked 2026-10-13 |
Battery claims use different conditions and are not a controlled benchmark. “Not verified” is an evidence gap, not a missing feature. Prices are dated regional snapshots. Deposits, bundles and historical launch prices are labelled. Brightness measurement methods and battery workloads vary by manufacturer.